Robots / Unitree G1 / G1 EDU
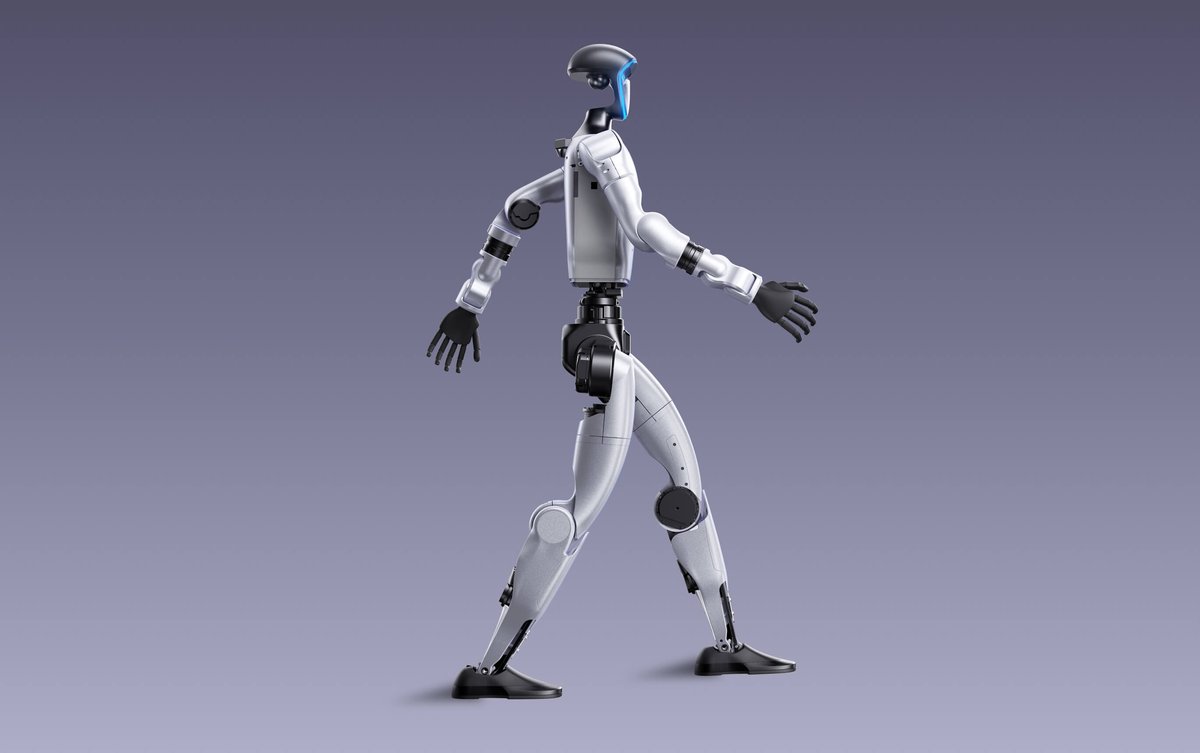
Unitree G1 / G1 EDU
A humanoid approx. 1.3 m tall for research on locomotion, manipulation and human–robot interaction. The EDU version opens up custom software development and Dex3-1 hands.
| Parameter | Value (manufacturer data) |
|---|---|
| Size (standing) | 1320 × 450 × 200 mm; folded 690 × 450 × 300 mm |
| Mass | approx. 35 kg; EDU "approx. 35 kg+" |
| DoF | 23; EDU: 23–43 |
| Arm payload | max approx. 2 kg; EDU approx. 3 kg |
| Battery, runtime | 9000 mAh quick-release; approx. 2 h |
| Speed | — |
| Sensors | depth camera + 3D LiDAR; 4-mic array; 5 W speaker |
| Compute | 8-core CPU; EDU: optional high-performance compute module |
| Secondary development | base: no; EDU: yes |
| SDK | unitree_sdk2 (g1: arm, audio, loco, agv) – github.com/unitreerobotics/unitree_sdk2 |
Source: www.unitree.com/g1/, read 21 Oct 2026. Lab figures from the manufacturer; real-world values may differ. We confirm the configuration in writing before you order.
Typical uses
- locomotion and reinforcement learning research (sim-to-real)
- manipulation with Dex3-1 hands
- human–robot interaction incl. speech and language models
- teaching
What you get from us
- choice of version and accessories for the task
- setup and operator training
- help with software and integration